A data product system for embodied intelligence training. Human real-world operations, hand-object interactions, robot motion, and real-to-sim synthetic data are continuously processed into annotatable, trainable, reusable datasets and skill assets.

Million-hourreal-world operation datasets
8data product lines, end to end
Cross-embodimentreuse via the WIOS interface

EGO Data: One Recording, Eight Modalities

Anchored on first-person video as the master timeline, the eight modalities compose on demand — all linked through a unified episode, timestamps and coordinate frames.

RGB · VIDEODEPTHMANOOBJECT 6DOFCAMERA SE(3)CONTACTLANGUAGERETARGET
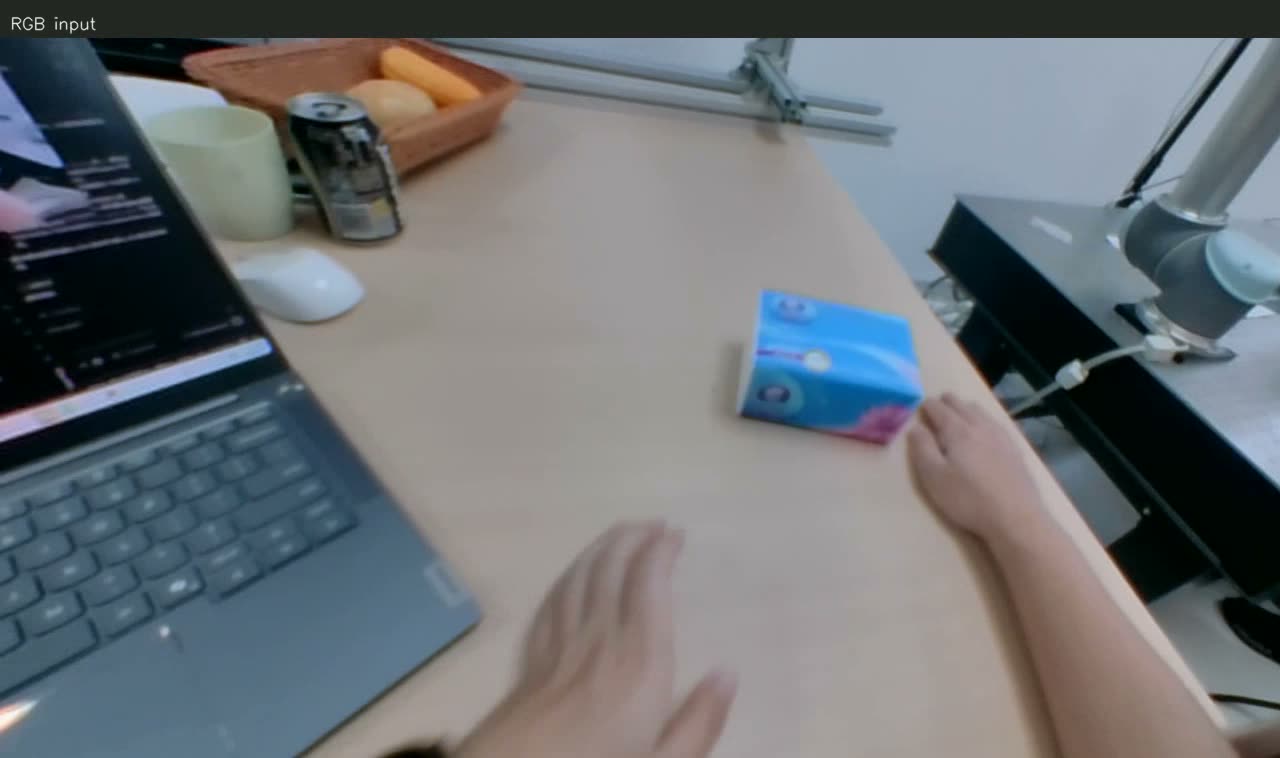
Raw first-person observation · unified timeline
FIG 01 — RGB INPUTOPEN →
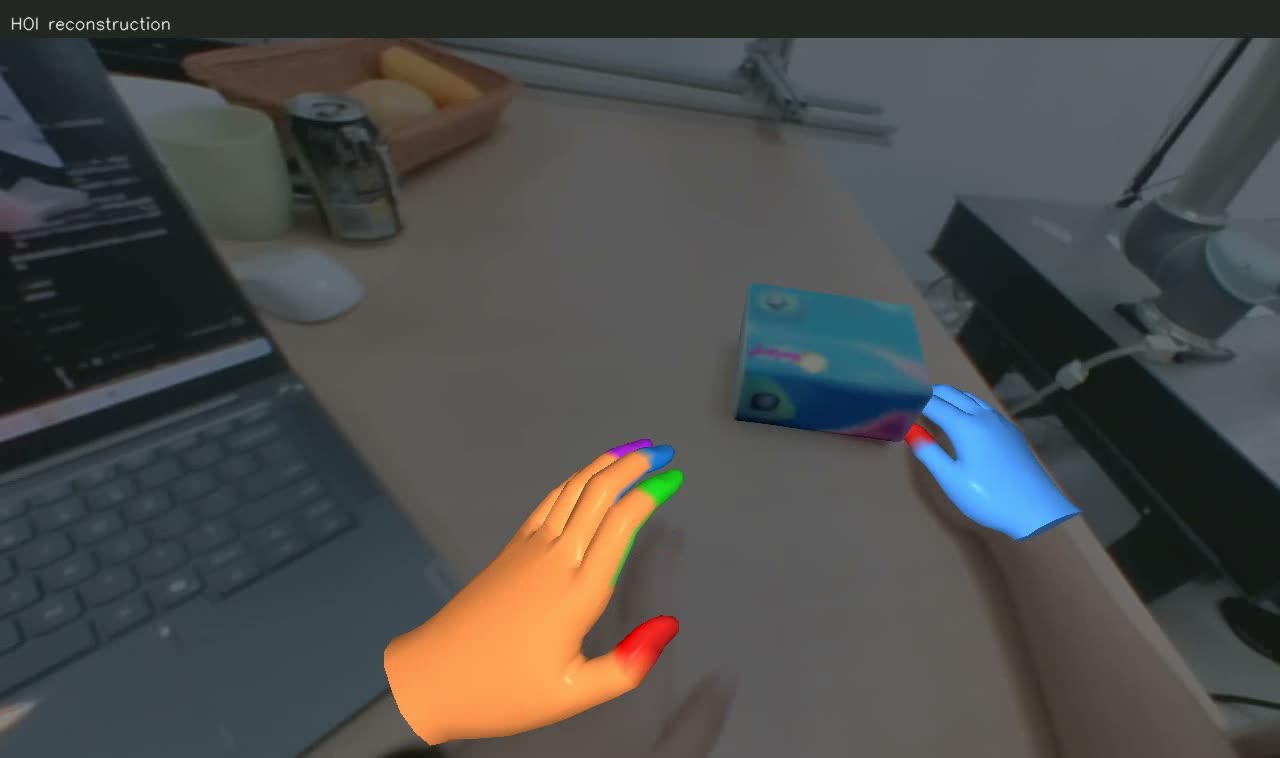
Dual-hand mesh reconstruction · color-coded fingertips
FIG 03 — HOI RECONSTRUCTIONOPEN →
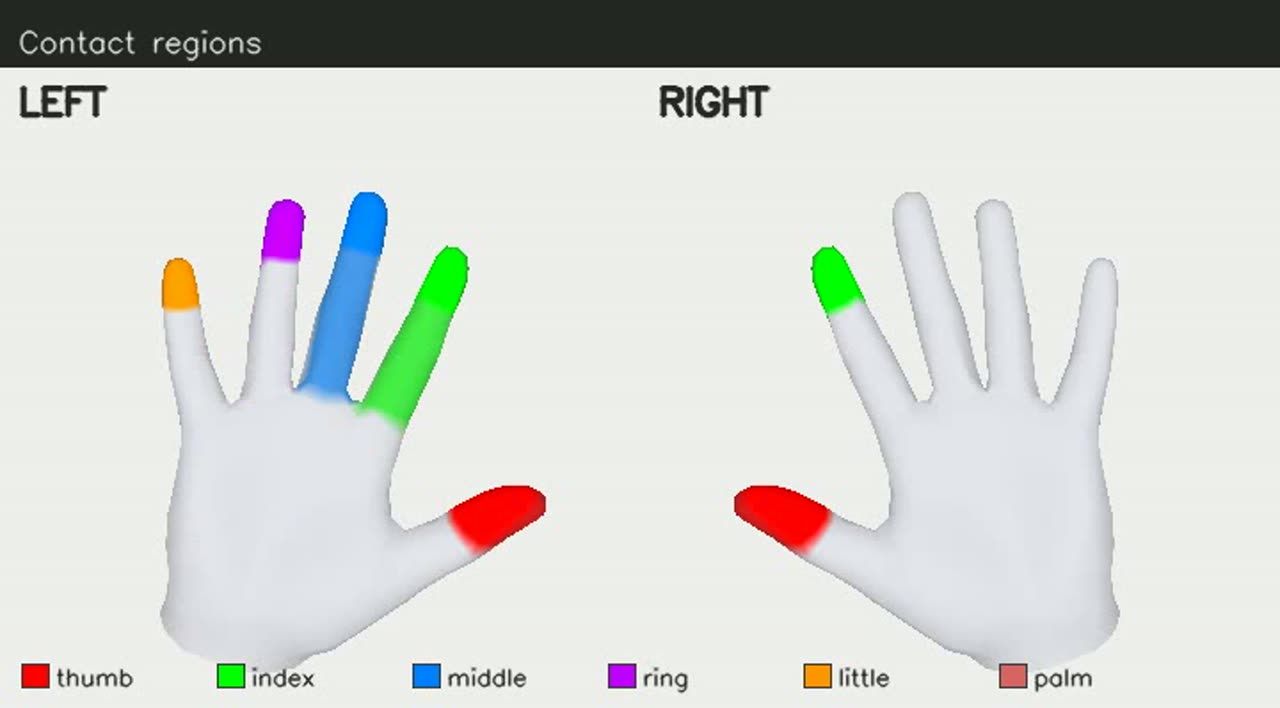
Fingertip-level contact color-coding
FIG 06 — CONTACT REGIONSOPEN →

From capture to skills — full-pipeline data processing

01

Multi-view capture

TSING-E²CAP devices, third-person cameras and robot bodies capture human motion, hand-object interaction and environmental context.

02

Human / hand modeling

Camera and sensor data is processed into parametric human and hand representations such as SMPL, SMPL-H, SMPL-X and MANO.

03

Semantic annotation

Task phases, action semantics, contact relations and object states are annotated to support fine-grained supervision for embodied models.

04

Real-to-sim synthesis

Real2Skill and sim2real-ready data are built with digital twins to extend coverage beyond real capture cost and distribution.

From real human data to robot skills

Following industry-leading data product logic: real-world task data is captured, standardized, and output as datasets and skill libraries compatible with LLMs and reinforcement learning.

Human / Hand Motion Library

High-precision SMPL / SMPL-H / SMPL-X human and hand motion library. Real human motion is parameterized into reusable body, hand and full-body pose representations for out-of-the-box motion libraries — powering humanoid priors, digital human driving, motion transfer and long-horizon task demos.

Ego / Third View Real Human Operation Videos

First- and third-person coverage of real scenes: observation paths, hand actions, object changes and environmental context. Built for vision models, task-phase recognition and embodied world models.

Ego / Third View MANO High-Precision Hand Modeling

A high-precision MANO parametric database around fine hand actions, providing hand pose, finger motion and manipulation trajectory supervision for VLA, world model, EgoScale, VITRA and other training frameworks.

Ego / Third View HOI High-Precision Modeling

A fine-grained HOI dataset around hand-object contact: contact state, object 6D pose, manipulation phase and outcome state — supporting imitation learning and human policy modeling.

Dexterous Manipulation Data

Multi-finger grasp, rotation, insertion, open/close, twisting, folding and other complex operations — focused on high-success-rate grasp policies and dexterous skill training for real objects and complex contact tasks.

Humanoid Locomotion Data

Simulation-ready data for gait, balance, turning, obstacle avoidance, navigation and upper-limb coordination — for locomotion policy training and simulation validation.

Real2Sim Robotic Data — 1:1 Real-Scene Reconstruction

Real task scenes are transformed into digital twin environments preserving objects, space, tasks and operation flows — for pre-deployment validation, policy stress testing and diversified sample expansion.

Sim2Real-Ready Cross-Domain Transfer Data

Robot-ready data packages for sim-to-real transfer that need no extra processing — helping teams shorten policy training, validation and deployment cycles.

Training-ready formats for VLA, world models, reinforcement learning and imitation learning: video, IMU, hand data, robot states, task metadata; human/hand parameters, object poses, contact relations, task phases.
Four Layers of Data Assets

Starting from raw multimodal capture, each layer matures into trainable datasets, reproducible simulation samples and transferable skill policies.

Raw capture

First/third-person multi-view raw footage that preserves the full scene and timeline — the source of every downstream asset.

Datasets

Parametric human and hand representations (SMPL family, MANO) with semantic labels, ready for VLA and world-model training.

Simulation samples

Digital-twin samples rebuilt 1:1 from real scenes — reproducible and extensible for Sim2Real transfer.

Skill policies

Task-level, transferable skill assets reused across embodiments through the unified WIOS interface.

ARCHIVE — 04 LAYERS STACKEDDATA ASSETS → WIOS REUSE

What holds the industry back is not the model — it's high-quality data

Turning real human operations into a trainable, reusable, out-of-the-box data engine — reused across embodiments via the unified WIOS interface, ready to power model training.

SYS / ACTIONREV 2026.08